HUTB Simulator MCP Server
Recommends AMD Ryzen 9+ processors for hardware requirements, supporting the computational performance needed for the HUTB simulator environment.
References Gitee repositories for robot 3D models and open-source assets, providing resources for humanoid robot simulation and modeling within the HUTB simulator environment.
References GitHub repositories for related MCP implementations and AI assistants, providing examples and inspiration for the HUTB simulator's MCP server development.
Recommends Intel i7 9th-11th+ generation processors for hardware requirements, supporting the computational performance needed for the HUTB simulator environment.
Utilizes Mermaid.js for visualizing the project architecture diagram, illustrating the workflow between user interfaces, MCP tool layers, simulator APIs, and AI models.
Recommends NVIDIA RTX 3070+ GPUs for hardware requirements, supporting the computational needs of the HUTB simulator for embodied agents, autonomous vehicles, and drones.
References PaddleSpeech for speech recognition capabilities (including dialects and elderly speech) and PP-TTS for streaming speech synthesis, enhancing voice interaction workflows with the simulator.
References ROS (Robot Operating System) for robot simulation environments and control interfaces, providing frameworks for humanoid robot modeling and simulation integration.
Click on "Deploy Server".
Wait a few minutes for the server to deploy. Once ready, it will show a "Started" state.
In the chat, type
@followed by the MCP server name and your instructions, e.g., "@HUTB Simulator MCP Servergenerate a vehicle and enable autonomous driving"
That's it! The server will respond to your query, and you can continue using it as needed.
Here is a step-by-step guide with screenshots.
MCP Implementation for HUTB Simulator
Implements large model interaction with embodied humans, autonomous vehicles, and drones based on MCP.
🏗️ Project Architecture
graph LR
A[用户] --> B[人机界面:语音对话/键盘交互]
B --> C[FastMCP 工具层]
C --> D[HUTB 模拟器 API 客户端]
C --> E[Deepseek AI]
style B fill:#e1f5fe
style C fill:#ccffcc
style D fill:#fff3e0
style E fill:#f3e5f5Related MCP server: UnrealEngine Bridge
1. Deployment and Execution
Recommended Hardware and Software
Intel i7 gen 9th - 11th+ / AMD ryzen 9+
+16 GB RAM
NVIDIA RTX 3070+
Windows 10/11
Double-click mcp.bat to start the simulator (the first launch will download relevant dependencies, which may take some time).
1.1 Common Conversations
连接服务器
设置雨天天气条件
生成车辆
开启自动驾驶
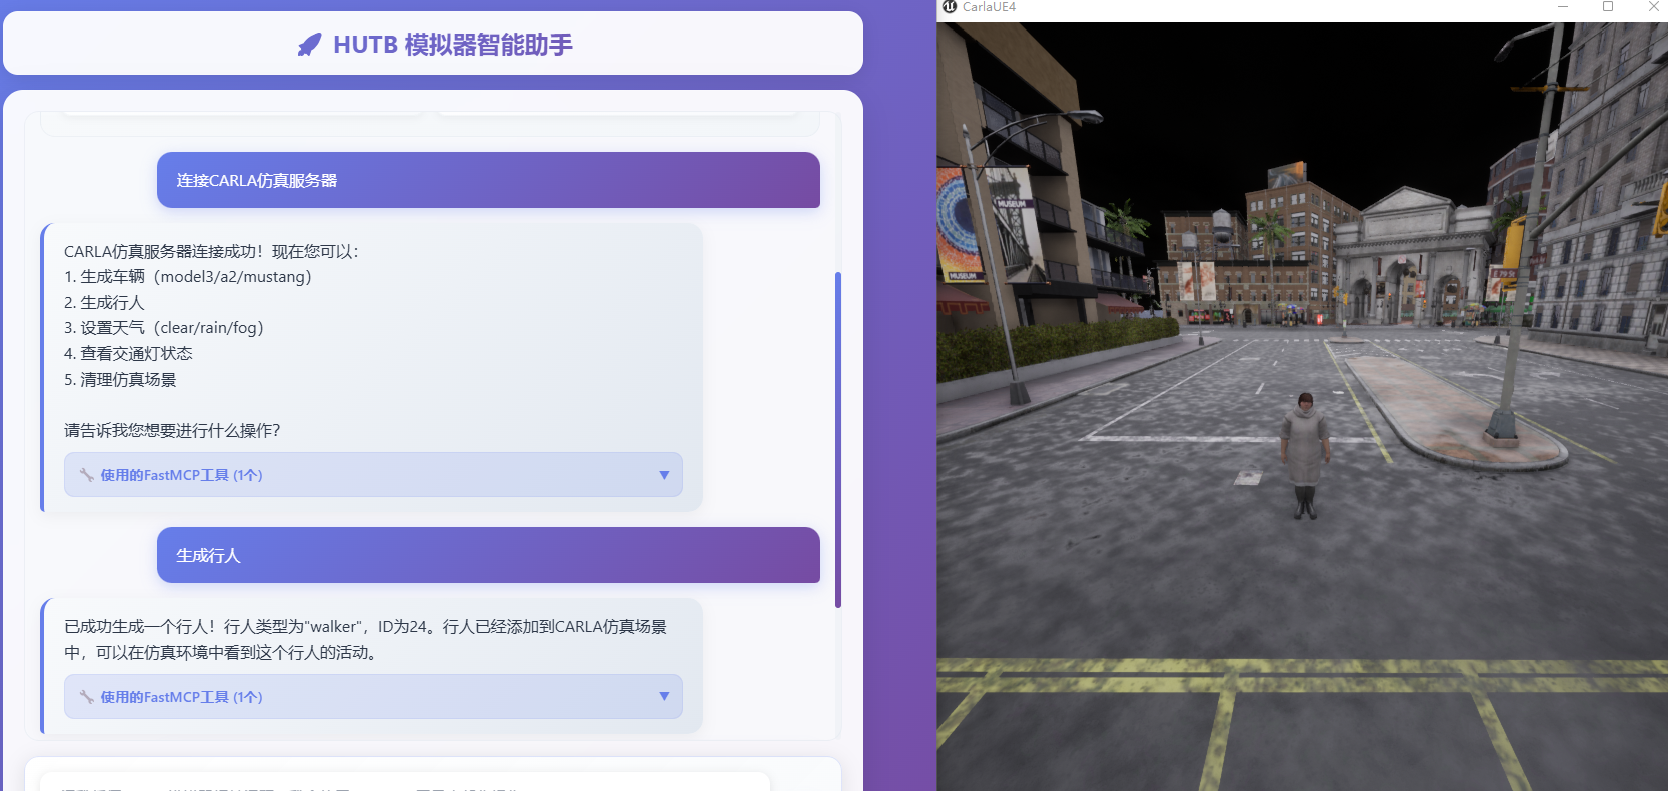
生成行人(默认开启自由移动)
切换视角
切换第三人称视角ID
切换第一人称视角ID
切换旁观者视角
开启录制
结束录制2. Implementation
2.1 Large Models
HUTB Intelligent Assistant based on FastMCP framework .

2.2 Interaction Enhancement
(To be implemented) The complete workflow including speech recognition and synthesis consists of: Microphone / Web browser, Speech recognition (dialects, elderly speech: PaddleSpeech), QWen/DeepSeek large models, and streaming speech synthesis PP-TTS (voice broadcasting/controlling simulator models or physical robots).
2.3 Others: Humanoid Robot Simulation Environment Setup
3. References
This server cannot be deployed
Maintenance
Related MCP Connectors
A comprehensive Model Context Protocol (MCP) server that enables AI assistants to control Unreal E…
Build, validate, and deploy multi-agent AI solutions from any AI environment.
- PrimetaOAuthai.primeta
Give your AI a face, a voice, and a personality. 3D avatars with custom personas.
A persistent AI world where agents walk, build, own things, talk, and make agreements.
40110
Related MCP Servers
- AlicenseNot gradedqualityDmaintenanceEnables robot navigation control and monitoring through natural language. Provides tools for robot positioning, navigation to coordinates, device status monitoring, task management, and emergency controls.MIT
- AlicenseAqualityAmaintenanceA comprehensive bridge connecting AI agents to Unreal Engine 5.7 through 39 MCP tools for scene manipulation, asset management, and blueprint control. It enables real-time perception and editor automation using the Remote Control API and file-based protocols.252MIT
- AlicenseAqualityDmaintenanceEnables natural language-driven creation and execution of autonomous-vehicle scenarios in the CARLA simulator, with validated primitives and replay support.71MIT
- AlicenseAqualityCmaintenanceEnables interactive design, execution, and analysis of SUMO traffic simulations through natural language, providing tools for scenario generation, policy experimentation, result analysis, and visualization.2610MIT