
LeCroy Oscilloscope MCP
# lecroy-mcp
MCP server for controlling LeCroy oscilloscopes via SCPI over LAN (VXI-11) or USB.
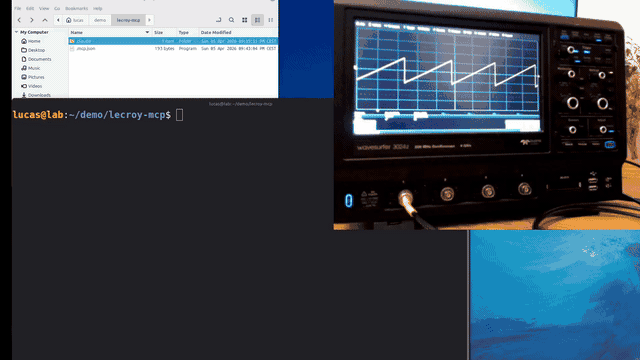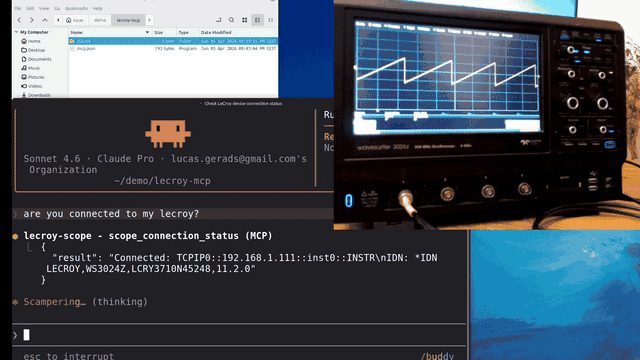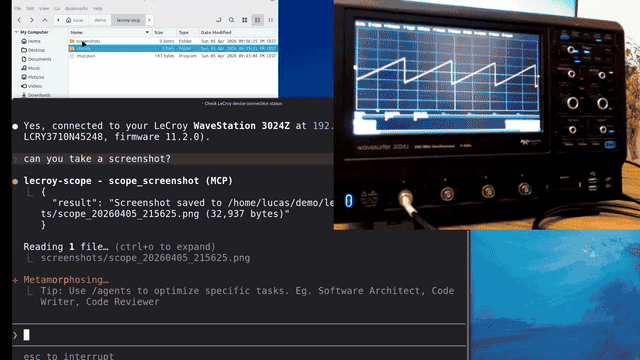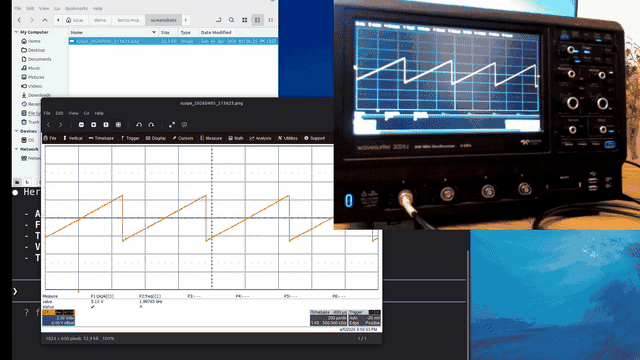
## Requirements
- [uv](https://docs.astral.sh/uv/) installed
- A LeCroy oscilloscope connected over LAN or USB
## MCP configuration
Add to your MCP client config (e.g. Claude Code's `.mcp.json`):
```json
{
"mcpServers": {
"lecroy-scope": {
"type": "stdio",
"command": "uvx",
"args": ["lecroy-mcp"]
}
}
}
```
`uvx` will automatically download and run the server — no manual installation needed.
## Oscilloscope setup (LAN / VXI-11)
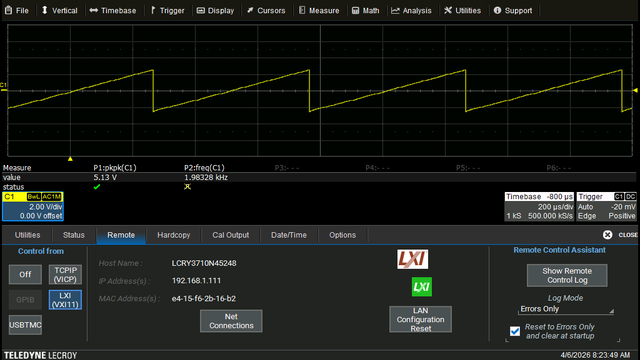
This server communicates over the standard VXI-11 protocol. Before connecting, enable it on the scope:
1. On the scope, go to **Utilities → Utilities Setup ... → Remote**
2. In the **Control from** section, enable **LXI (VXI11)**
3. Note the **IP Address** shown — you will need it for the connection string
The scope's IP can be assigned via DHCP or configured statically under **Utilities → Utility → Remote → Net Connections**.
> **Note:** The **TCPIP (VICP)** option shown in the same panel uses LeCroy's proprietary protocol and is currently not supported by this server. Only **LXI (VXI11)** is required.
## Connection options
### Option 1 — Manual connection
Copy the MCP client config from above as-is and connect from within the Claude session:
1. `scope_scan` — auto-detect LeCroy scopes on the local network
2. `scope_list_resources` — list all VISA resources (LAN + USB)
3. `scope_connect("TCPIP0::192.168.1.111::inst0::INSTR")` — connect directly
Optionally set `LECROY_SUBNET` to hint the scan range:
```json
{
"mcpServers": {
"lecroy-scope": {
"type": "stdio",
"command": "uvx",
"args": ["lecroy-mcp"],
"env": {
"LECROY_SUBNET": "192.168.1.0/24"
}
}
}
}
```
### Option 2 — Pre-configure the IP address (recommended for LAN)
Set `LECROY_HOST` in the env block and the server auto-connects on startup:
```json
{
"mcpServers": {
"lecroy-scope": {
...
"env": {
"LECROY_HOST": "192.168.1.111"
}
}
}
}
```
### Option 3 — Pre-configure a full resource string (LAN or USB)
Use `LECROY_RESOURCE` for full control, including USB connections:
```json
{
"mcpServers": {
"lecroy-scope": {
...
"env": {
"LECROY_RESOURCE": "USB0::0x05FF::0x1023::12345::INSTR"
}
}
}
}
```
## Usage
Once connected, you have tools for:
- Channel setup (scale, offset, coupling, bandwidth limit)
- Trigger configuration (mode, source, level, edge)
- Timebase and memory depth
- Automated measurements (PKPK, FREQ, RMS, RISE, DUTY, etc.)
- Waveform capture (JSON or CSV)
- Screenshots
- Math functions (FFT, INTG, DIFF, etc.)
- WaveSource built-in generator (WaveSurfer 3000Z and similar)
## Supported models
The server detects the connected model and adjusts commands accordingly.
Profiles are included for:
- WaveSurfer 3000Z / 4000HD
- HDO4000A / HDO6000B / HDO8000A
- WaveRunner 6000 / 8000
- WavePro HD
- MDA800A, SDA
Unknown models fall back to conservative defaults.
## Manual installation
If you prefer not to use `uvx`:
```bash
pip install lecroy-mcp
```
Then use `lecroy-mcp` as the command in your MCP config instead of `uvx lecroy-mcp`.
## Updating
With `uvx`, use the `@latest` tag to force the newest version:
```bash
uvx lecroy-mcp@latest
```
Or update the `args` in your `.mcp.json` to always pull the latest:
```json
"args": ["lecroy-mcp@latest"]
```
With pip:
```bash
pip install --upgrade lecroy-mcp
```
## Notes
- Requires `pyvisa-py` backend — NI-VISA is currently not supported (breaks screenshot capture)
- All VISA access is serialized via a threading lock; parallel MCP tool calls are safe
## Troubleshooting
**Diagnostic messages not appearing in MCP logs**
If you are not seeing server log output (e.g. auto-connect status or errors) in your MCP client's log viewer, add `PYTHONUNBUFFERED` to the env block:
```json
"env": {
"PYTHONUNBUFFERED": "1"
}
```
This disables Python's output buffering so log messages are flushed immediately. It is not required for normal operation.
## Tested with
| Component | Details |
|-----------|---------|
| Oscilloscope | Teledyne LeCroy WaveSurfer 3024Z |
| Operating system | Windows 10, Windows 11, Linux Mint |
| MCP client | Claude Code |
This server should also work with other MCP-compatible clients such as OpenAI Codex and Google Gemini Code Assist, and on other operating systems such as macOS. Reports and contributions for additional configurations are welcome.
## Disclaimer
Teledyne LeCroy and LeCroy are registered trademarks of Teledyne LeCroy, Inc. This project is an independent open-source tool and is not affiliated with, endorsed by, or sponsored by Teledyne LeCroy, Inc. All product and company names are trademarks or registered trademarks of their respective holders.
TDQS
Scored across 48 tools
Each tool targets a distinct operation (e.g., connect, configure_channel, measure, capture_waveform) with clear boundaries. Even similar tools like scope_measure and scope_measure_all are well-differentiated by scope. No ambiguity.
All tools follow a consistent 'scope_verb_noun' pattern (e.g., scope_connect, scope_configure_channel, scope_set_tdiv). The naming is predictable and uniform across the entire set.
48 tools is very high for an MCP server. While the oscilloscope domain is complex, the number exceeds the threshold for 'too many' (25+). Many tools could be consolidated or exposed as parameters of fewer tools.
The tool set covers nearly all oscilloscope operations: connection, channels, timebase, trigger, measurements, math, cursors, screenshot, wavesource, memory. Minor gaps exist (e.g., no tool to configure serial decode settings, only reading is provided).