Opentrons MCP Server
A Model Context Protocol (MCP) server for Opentrons robot automation and API documentation. This tool provides both comprehensive API documentation and direct robot control capabilities for Opentrons Flex and OT-2 robots.
Features
API Documentation Tools
Search Endpoints: Find API endpoints by functionality, method, or keyword
Endpoint Details: Get comprehensive information about specific API endpoints
Category Browsing: List endpoints by functional category
API Overview: High-level overview of the entire Opentrons HTTP API
Robot Automation Tools
Protocol Management: Upload, list, and manage protocol files
Run Control: Create runs, start/stop execution, monitor progress
Robot Health: Check connectivity and system status
Hardware Control: Home robot, control lights, and basic operations
Related MCP server: MCP Documentation Server
Installation
From npm (recommended)
npm install -g opentrons-mcp
From source
git clone https://github.com/yerbymatey/opentrons-mcp.git
cd opentrons-mcp
npm install
Configuration
Add to your Claude Desktop configuration file:
macOS: ~/Library/Application Support/Claude/claude_desktop_config.json
Windows: %APPDATA%\Claude\claude_desktop_config.json
{
  "mcpServers": {
    "opentrons": {
      "command": "opentrons-mcp",
      "args": []
    }
  }
}
If installed from source:
{
  "mcpServers": {
    "opentrons": {
      "command": "node",
      "args": ["/path/to/opentrons-mcp/index.js"]
    }
  }
}
Available Tools
Documentation Tools
search_endpoints
Search Opentrons HTTP API endpoints by functionality, method, path, or keyword.
query (required): Search term
method (optional): Filter by HTTP method (GET, POST, PUT, DELETE, PATCH)
tag (optional): Filter by API category
include_deprecated (optional): Include deprecated endpoints
get_endpoint_details
Get comprehensive details about a specific API endpoint.
list_by_category
List all endpoints in a specific functional category.
get_api_overview
Get high-level overview of the Opentrons HTTP API structure and capabilities.
Automation Tools
upload_protocol
Upload a protocol file to an Opentrons robot.
robot_ip (required): Robot IP address
file_path (required): Path to protocol file (.py or .json)
protocol_kind (optional): "standard" or "quick-transfer" (default: "standard")
key (optional): Client tracking key
run_time_parameters (optional): Runtime parameter values
get_protocols
List all protocols stored on the robot.
create_run
Create a new protocol run on the robot.
robot_ip (required): Robot IP address
protocol_id (required): ID of protocol to run
run_time_parameters (optional): Runtime parameter values
control_run
Control run execution (play, pause, stop, resume).
robot_ip (required): Robot IP address
run_id (required): Run ID to control
action (required): "play", "pause", "stop", or "resume-from-recovery"
get_runs
List all runs on the robot.
get_run_status
Get detailed status of a specific run.
robot_health
Check robot health and connectivity.
control_lights
Turn robot lights on or off.
home_robot
Home robot axes or specific pipette.
robot_ip (required): Robot IP address
target (optional): "robot" for all axes, "pipette" for specific mount
mount (optional): "left" or "right" (required if target is "pipette")
Usage Examples
With Claude Desktop
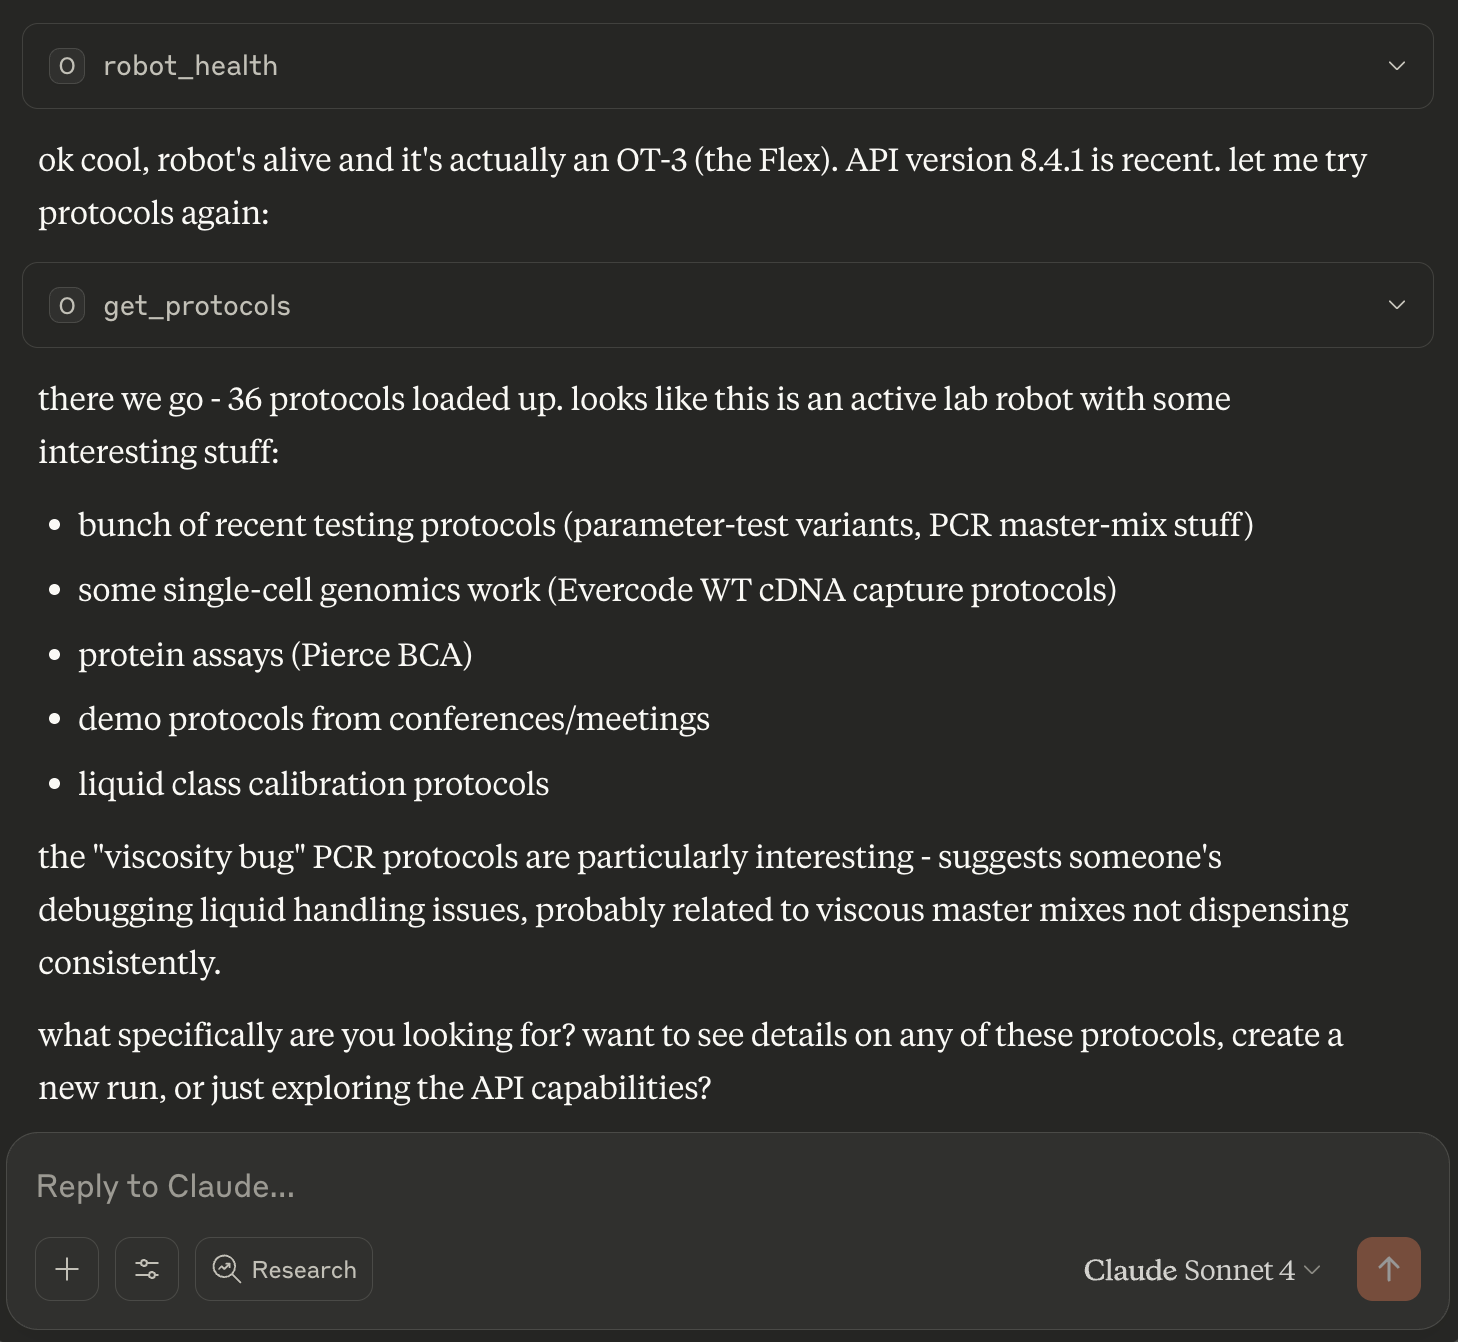 Screenshot showing the Opentrons MCP server in action with Claude Desktop after asking for current protocols with opentrons for the Flex, give it the robot ip!
Once configured, you can use natural language to control your robot:
Upload a protocol:
Upload the protocol file at /path/to/my_protocol.py to my robot at 192.168.1.100
Check robot status:
Check if my robot at 192.168.1.100 is healthy and ready
Run a protocol:
List all protocols on my robot, then create and start a run for the latest one
Monitor progress:
Show me the status of run abc123 on my robot
Programmatic Usage
import { Client } from "@modelcontextprotocol/sdk/client/index.js";

// Connect to MCP server
const client = new Client(/* transport */);

// Upload protocol
await client.request({
  method: "tools/call",
  params: {
    name: "upload_protocol",
    arguments: {
      robot_ip: "192.168.1.100",
      file_path: "/path/to/protocol.py",
      protocol_kind: "standard"
    }
  }
});
Requirements
Robot Setup
Ensure your Opentrons robot is:
Connected to the same network as your client
Running robot software version 7.0.0+
Accessible on port 31950 (default for HTTP API)
You can verify connectivity by visiting http://your-robot-ip:31950/health in a browser.
API Reference
This tool provides access to the complete Opentrons HTTP API, including:
Protocol Management: Upload, analyze, and manage protocol files
Run Management: Create, control, and monitor protocol runs
Hardware Control: Robot movement, homing, lighting, and calibration
System Management: Health monitoring, settings, and diagnostics
Module Control: Temperature modules, magnetic modules, thermocyclers
Data Management: CSV files for runtime parameters
For detailed API documentation, use the search and documentation tools provided by this MCP server.
Troubleshooting
Cannot connect to robot
Verify robot IP address is correct
Ensure robot is powered on and connected to network
Check that port 31950 is accessible
Confirm robot software is running
Protocol upload fails
Verify file path exists and is readable
Ensure protocol file is valid Python (.py) or JSON format
Check available disk space on robot
Confirm protocol is compatible with robot type (OT-2 vs Flex)
Run execution issues
Verify all required labware and modules are attached
Check robot calibration status
Ensure protocol analysis completed successfully
Confirm no hardware errors or conflicts
Contributing
Contributions are welcome! Please feel free to submit issues and pull requests.
License
No license go brazy
Related Projects


